Flight Tuning
Flight Tuning holds the settings you change most at the field: PIDs, rates, the governor and the rotor settings. The pages are the same settings as the Configurator's, so each section below links to the page that explains them.
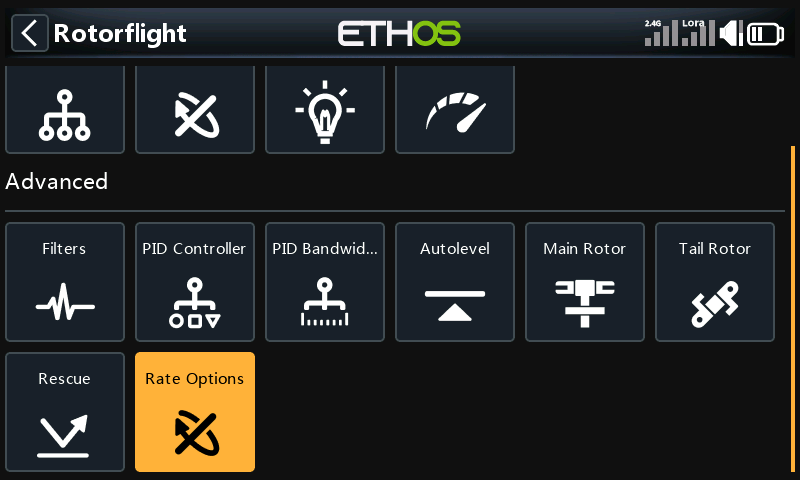
The menu scrolls: below Advanced there is a further row with Rescue and Rate Options.
Most of these pages belong to a PID or rate profile, shown in the title as PIDs #1 and so on. To work on another profile, switch to it (from the radio, or with Select Profile) and the page follows.
PIDs
P, I, D, F, O and B for roll, pitch and yaw.
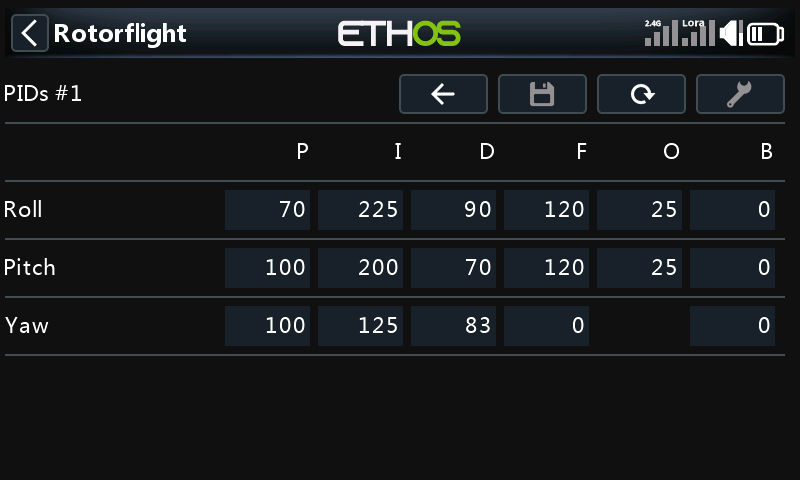
See Profiles.
Rates
RC Rate, Rate and RC Expo for roll, pitch, yaw and collective, for the active rate profile. The column headings follow the rate type chosen under Rate Options → Rate Table.
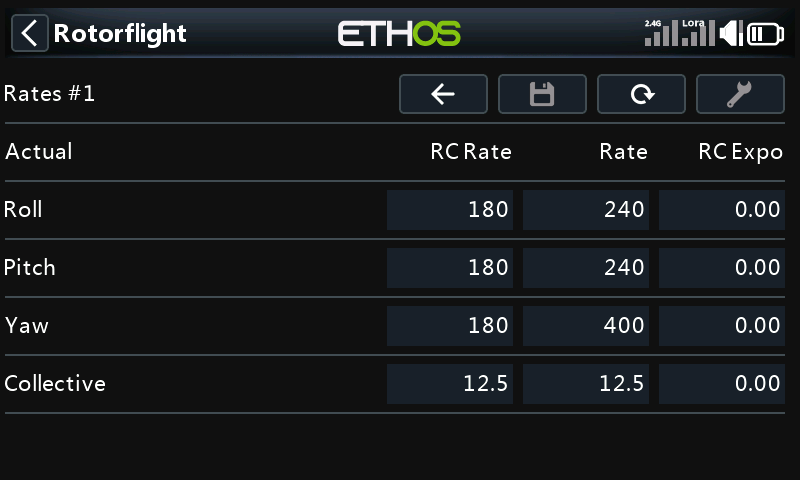
See Rates.
Tune Advisor
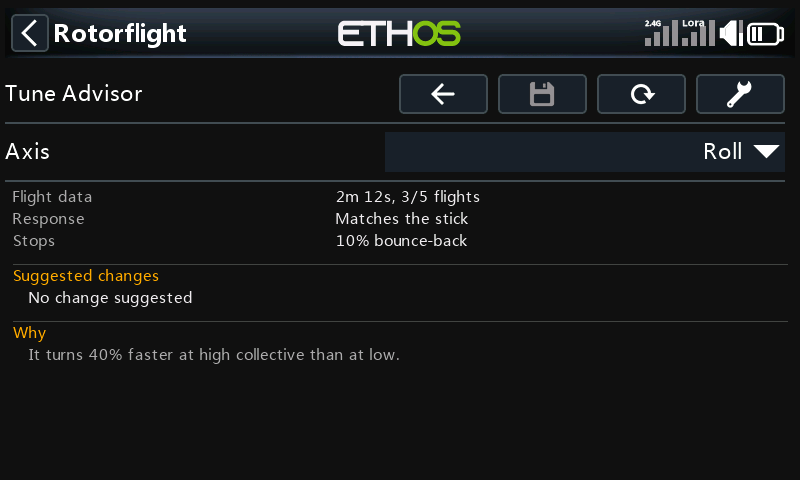
Unlike the other pages, the Tune Advisor is the radio's own. While you fly in rate mode, the flight controller measures how the model answers the sticks, and each time you disarm the radio stores that flight's results. Pick an axis to see how it responds and stops, and what the advisor suggests changing and why. Tool clears the data it has collected.
Governor
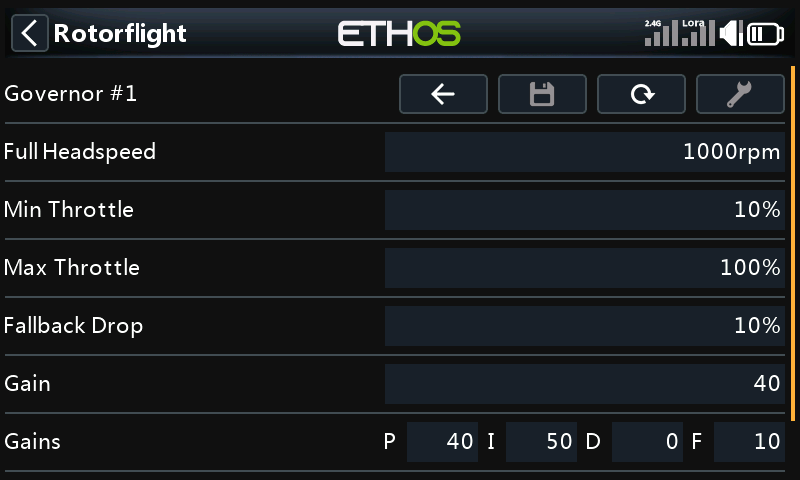
The governor's per-profile settings, in two pages: General (head speed, throttle limits, fallback drop and gains) and Behaviour (precomp, spoolup, voltage compensation and dynamic minimum throttle). The governor's mode and timing are under Setup → Governor.
See Governor and Tune Governor.
Filters
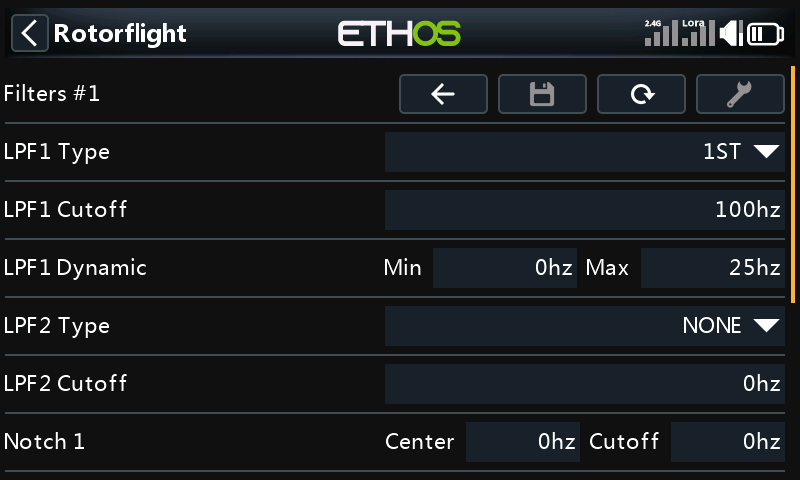
The gyro lowpass filters (type, cutoff, and dynamic range) and the notch filters. The page scrolls.
See First Flight Filter Tuning.
PID Controller
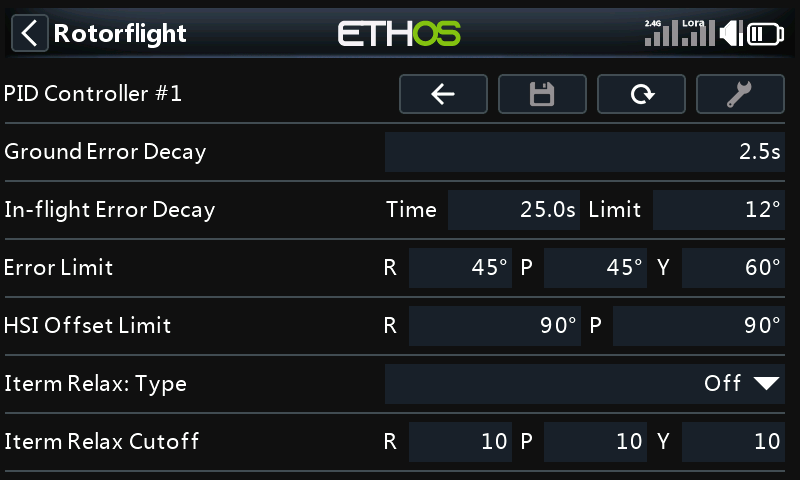
How the PID loop handles error: ground and in-flight error decay, error limits, HSI offset limit and I-term relax. The page scrolls.
See Profiles.
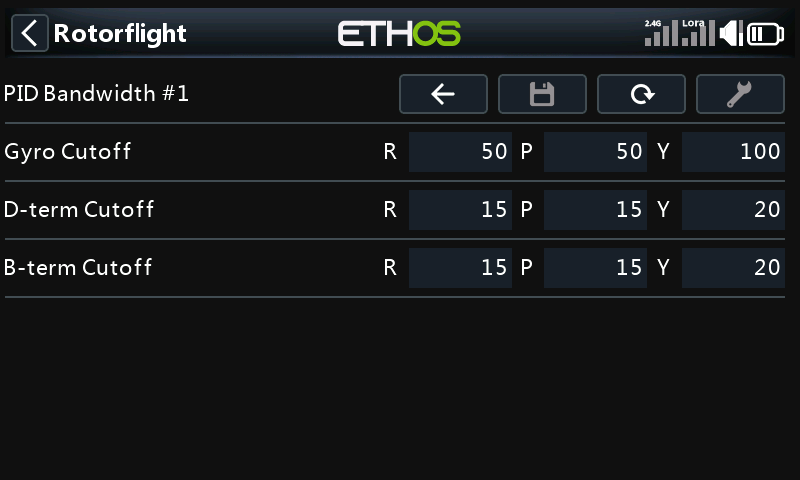
PID Bandwidth
Cutoff frequencies for the gyro, D-term and B-term, per axis.
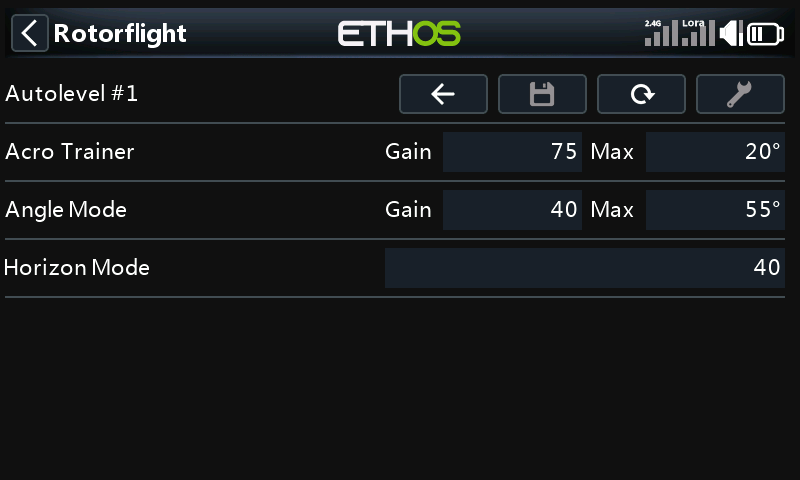
Autolevel
Gain and maximum angle for Acro Trainer and Angle mode, and the Horizon mode gain.
See Modes.
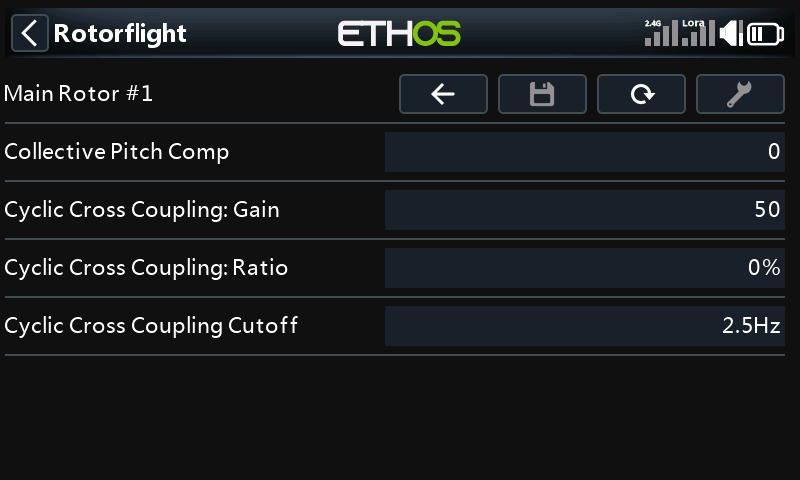
Main Rotor
Collective pitch compensation and cyclic cross coupling.
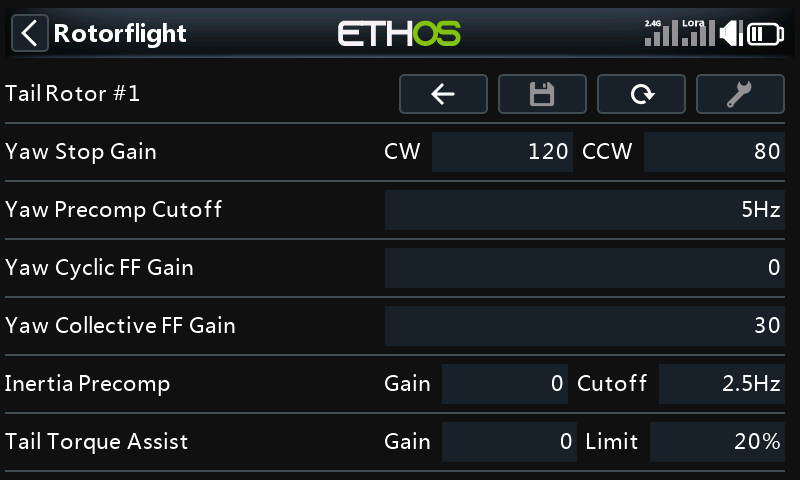
Tail Rotor
Yaw stop gains, precomp, inertia precomp and tail torque assist.
Rescue
Rescue mode: whether it flips to upright, and the pull-up, climb, hover and flip stages. The page scrolls.
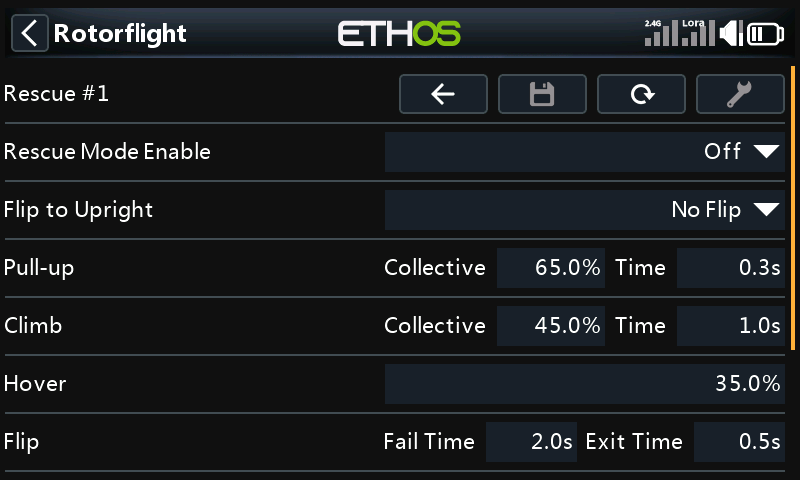
See Rescue Mode Settings.
Rate Options
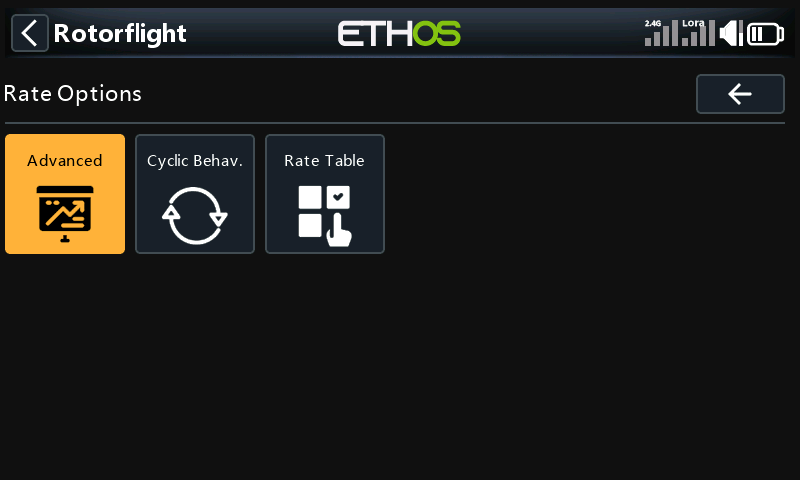
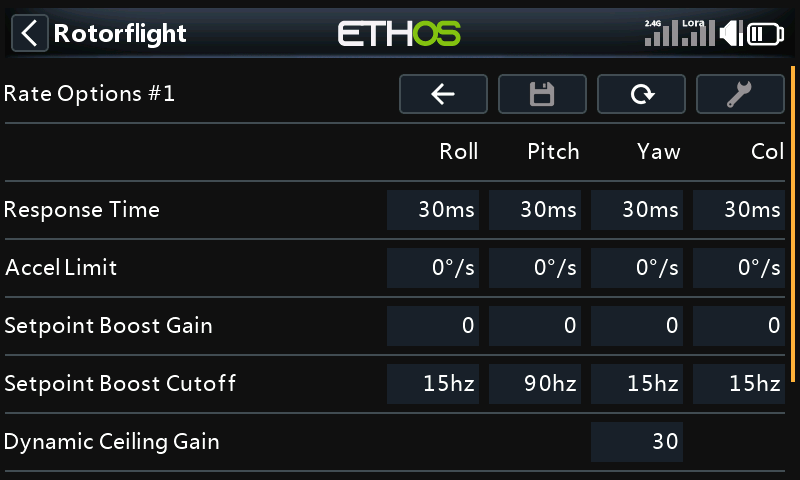
A menu of three pages: Advanced (response time, acceleration limit, setpoint boost and dynamic ceiling gain per axis), Cyclic Behav. (cyclic ring and polarity) and Rate Table (the rate type the Rates page uses).
See Rates.